- All products
- Force torque sensors
- PixONE Gen A
- Force torque sensors
PixONE Gen A
For OEM use cases. Design your system specifically for the sensor.
Choose an evaluation adapter to test the sensor before integration.
This product is no longer available.
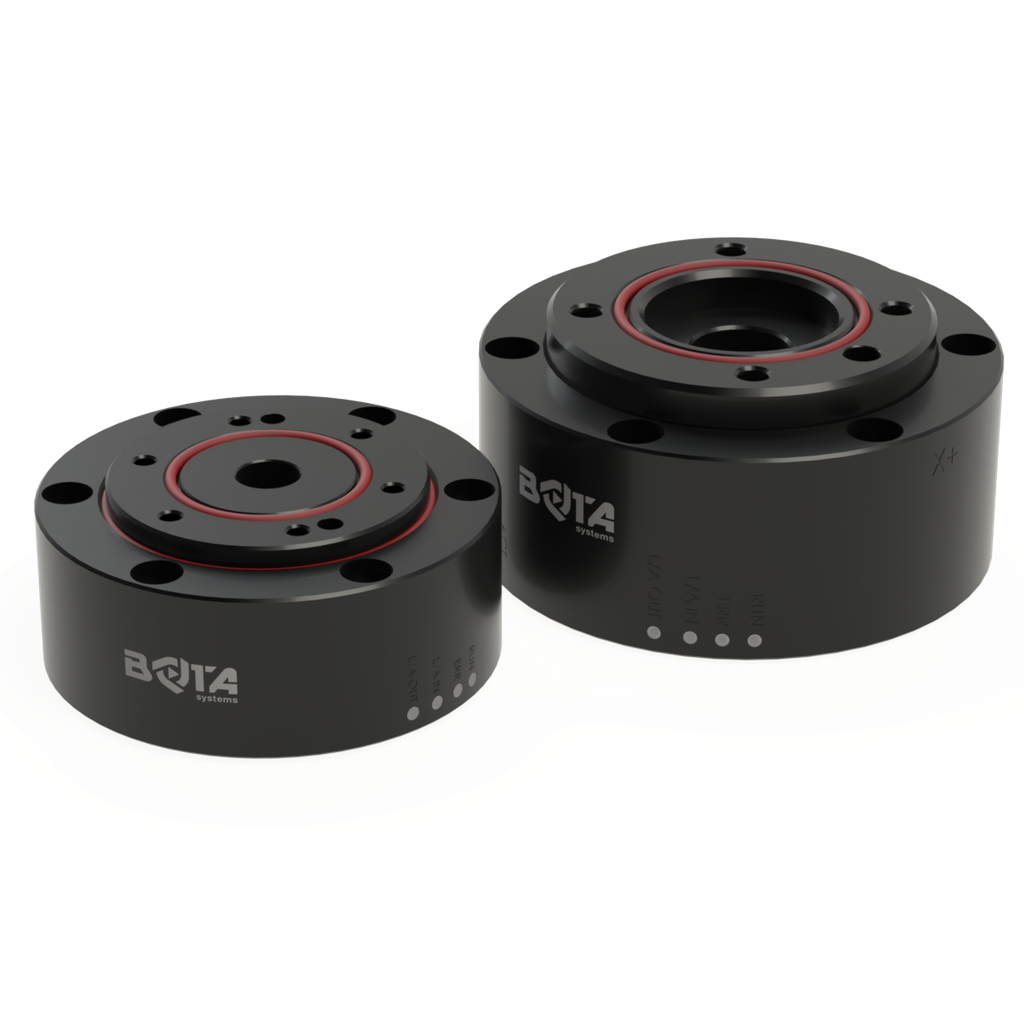
Force sensing for your robot
▶ Design, smooth body to seamlessly integrate with your robot design
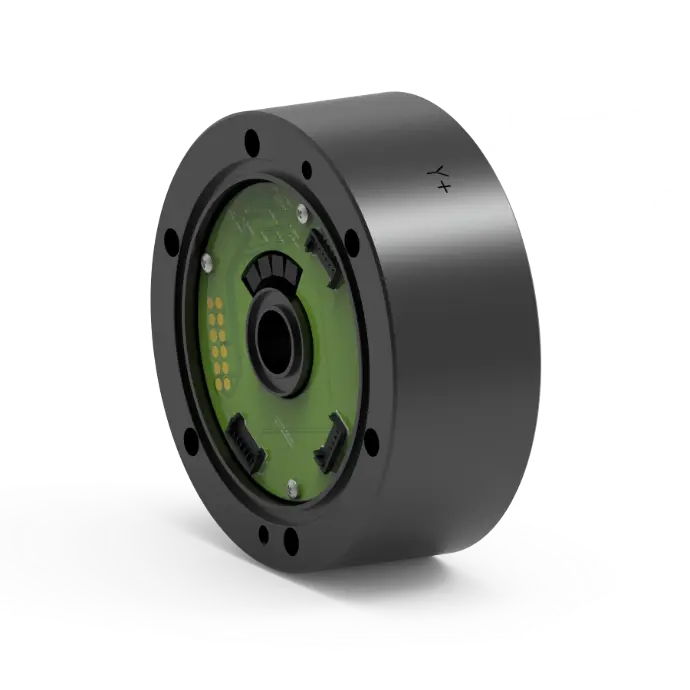
▶ All protocols, available on internal connection.
▶ Through Hole, pass-through design to the End-effector.
▶ Daisy chain, use the through hole to daisy chain EtherCAT or Modbus protocols
▶ Medical Ready, internal wiring allows for a smooth and easy to clean sensor body, full traceability.
A variety of protocols with
low-latency
▶ PoE Ethernet, RS422/485/232, Modbus and USB for instant integration and configuration using our online config tool.
▶ EtherCAT IN and OUT, with USB for commissioning using our online config tool.
▶ Spring-loaded Contacts, for minimizing assembly cost.
Performance
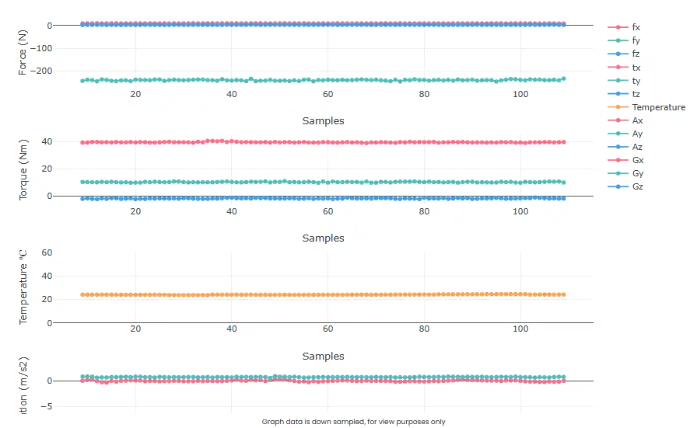
▶ 3800Hz sampling rate, supported in all protocols
▶ Low drift, stability over time in all 6-axes with our patented design
▶ Low latency, with native protocol implementation ensuring up to 1 sample latency
O-Ring level Protection
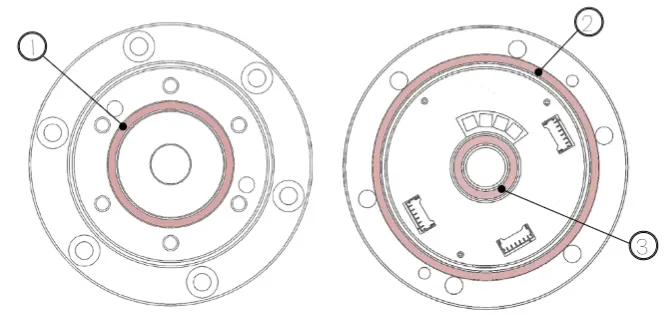
▶ Up to 1m, submersible for 30 mins
▶ waterjets, protection from from every angle
▶ Fine dust, protection
▶ Through-hole, protection
Initial setup in no time
▶ Evaluation kits, for fast evaluation and software integration directly mount on ISO 50 Flange
▶ Online config for easy commissioning.
▶ Guides & Tutorials to guide you through the integration
▶ Example designs to ease the design of the system.

Choose Range Variant
| PixONE T25 | Fx | Fy | Fz | Mx | My | Mz |
|---|---|---|---|---|---|---|
| Range | 1000 N | 1000 N | 1800 N | 25 Nm | 25 Nm | 25 Nm |
| Overload limit* | 2800 N | 2800 N | 7500 N | 80 Nm | 80 Nm | 140 Nm |
| Noise Free Resolution** | 0.15 N | 0.15 N | 0.15 N | 0.008 Nm | 0.008 Nm | 0.001 Nm |
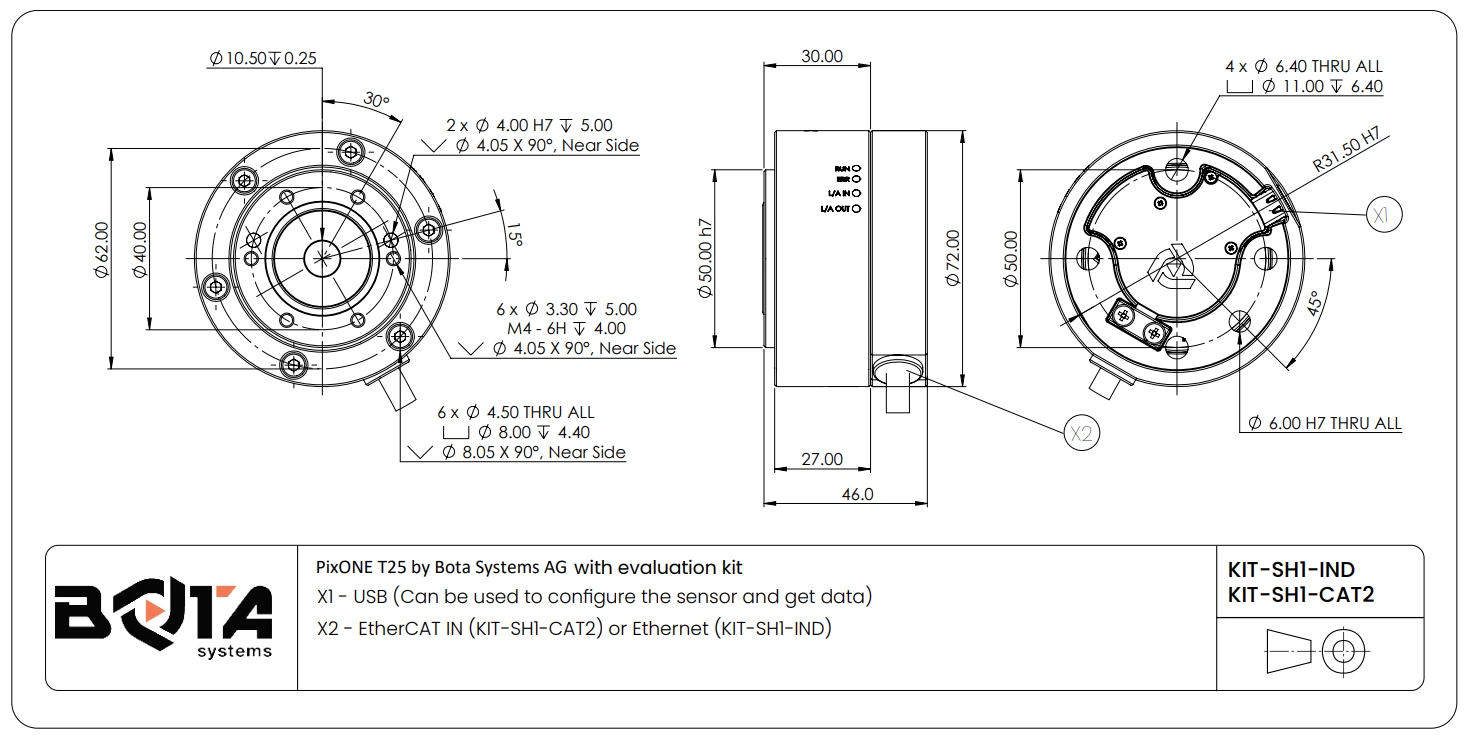
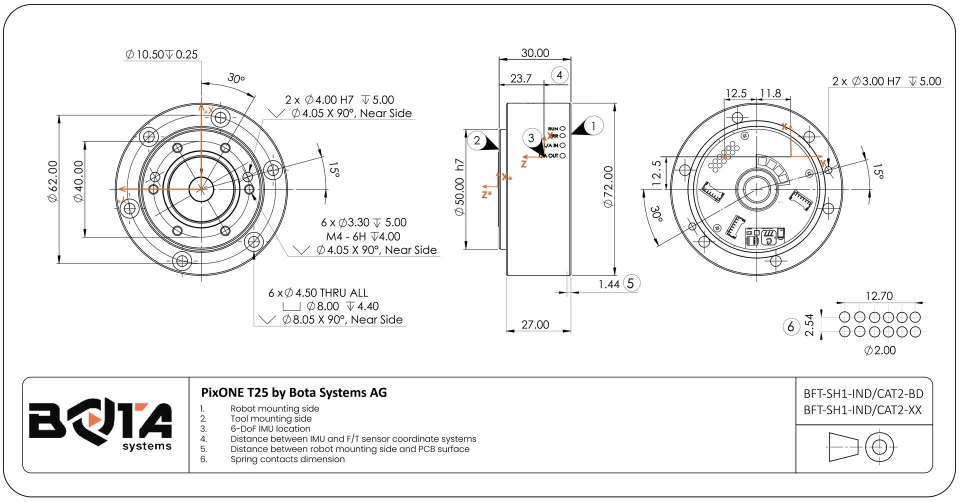
| Size (D x H) | 72 mm x 30 mm |
| Maximum sampling rate | 3800 Hz |
| IMU | 6 DoF IMU, accelerometer & gyroscope |
| Acceleration | ±16g |
| Gyroscope | ±2000°/sec |
| Ingress protection | Dust and water resistant |
| Operating temperature | 0°C – 55°C |
| Power supply | 5-60V (75V max), 1.5W |
| Weight | ~236 grams |
| Interface Variant | Industrial | EtherCAT |
|---|---|---|
| Communication | Ethernet 100Mbps, Serial RS422/RS232/RS485, USB | EtherCAT In/Out, USB |
| Protocol | Modbus TCP/RTU, Bota protocol**, VCP*** | CoE****, Bota protocol**, VCP*** |
| PixONE T60 | Fx | Fy | Fz | Mx | My | Mz |
|---|---|---|---|---|---|---|
| Range | 1800 N | 1800 N | 4000 N | 60 Nm | 60 Nm | 50 Nm |
| Overload limit* | 7200 N | 7200 N | 12800 N | 160 Nm | 160 Nm | 200 Nm |
| Noise Free Resolution** | 0.35 N | 0.35 N | 0.20 N | 0.01 Nm | 0.01 Nm | 0.003 Nm |
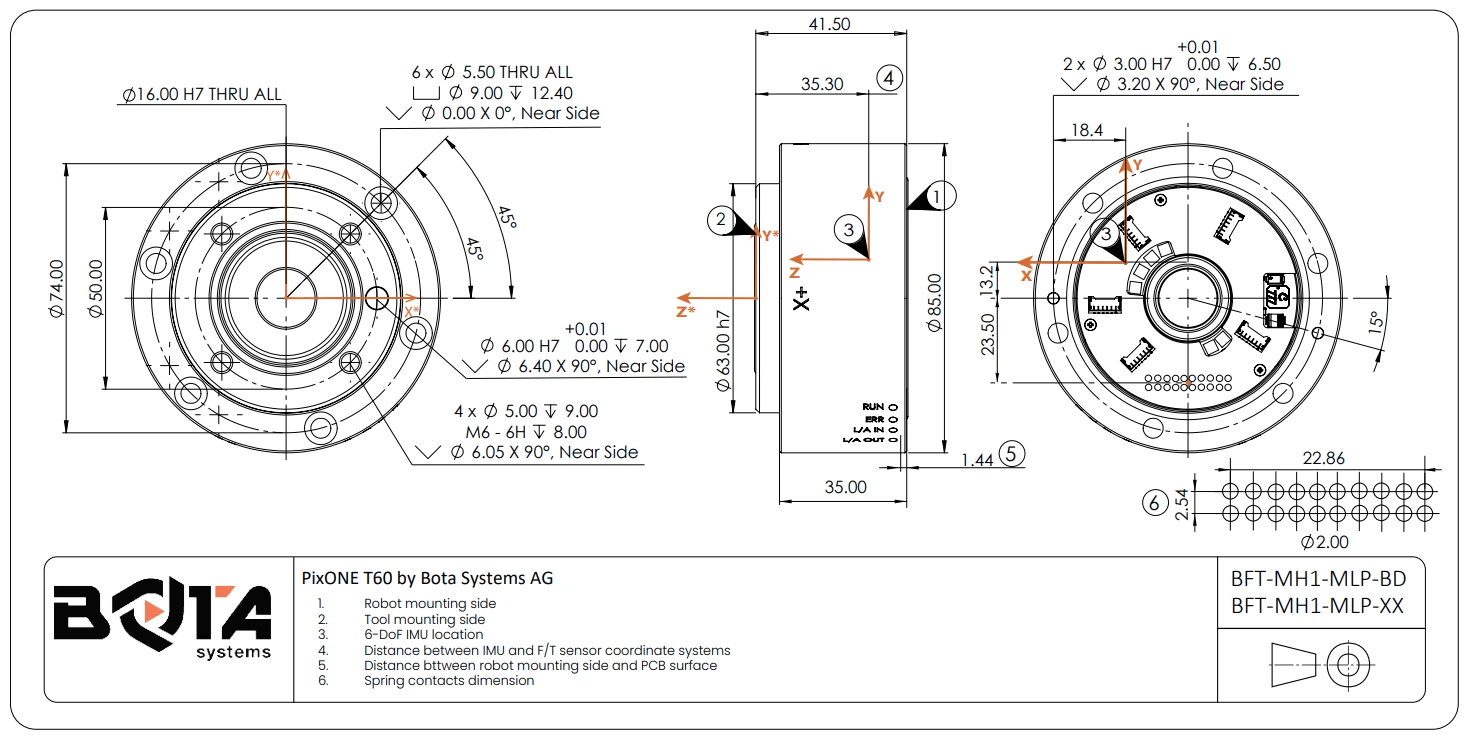
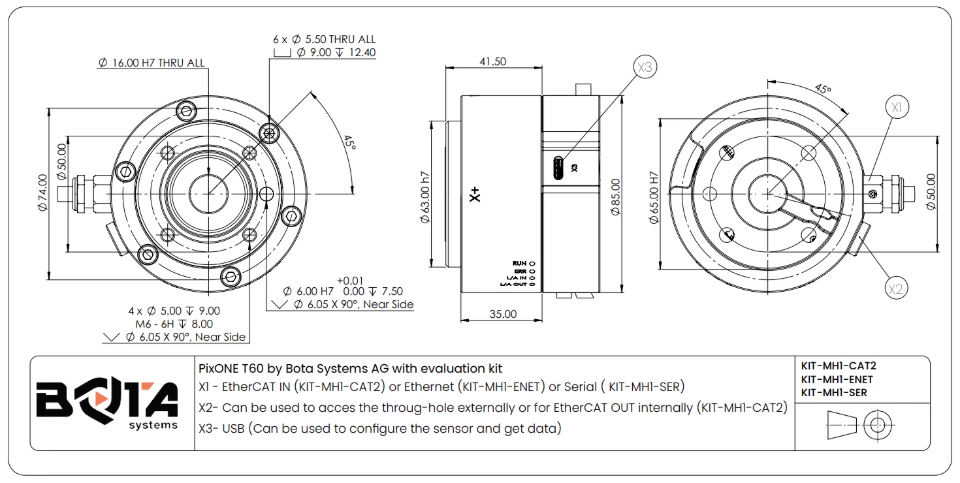
| Size (D x H) | 85 mm x 41.5 mm |
| Maximum sampling rate | 3800 Hz |
| IMU | 6 DoF IMU, accelerometer & gyroscope |
| Acceleration | ±16g |
| Gyroscope | ±2000°/sec |
| Ingress protection | Dust and water resistant |
| Operating temperature | 0°C – 55°C |
| Power supply | 5-60V (75V max), 1.5W |
| Weight | ~436 grams |
| Interface Variant | Multiprotocol |
|---|---|
| Communication | Ethernet 100Mbps, Serial RS422/RS485, EtherCAT In/Out, USB |
| Protocol | Modbus TCP/RTU, Bota protocol*, VCP**, CoE*** |
Product codes (PN) related to this product: BFT-MH1-MLP-BD, BFT-SH1-CAT2-BD, BFT-SH1-IND-BD, KIT-MH1-CAT2, KIT-MH1-ENET, KIT-MH1-SER, KIT-SH1-CAT, KIT-SH1-NET, KIT-SH1-SER
Choose Range & Adapter Variant
Choose Interface Variant